
ESP32 MicroPython DRV8833 DC Motor Driver
This tutorial instructs you how to use the DRV8833 motor driver with the ESP32 and MicroPython. In detail, we will learn:
- How the DRV8833 module works, and what each of its pins does.
- How to wire one DC motor to a ESP32 through the DRV8833, and write MicroPython code to change its speed and direction.
- How to add a second DC motor and drive both of them like the wheels of a small robot car.
Hardware Preparation
Or you can buy the following kits:
| 1 | × | DIYables ESP32 Starter Kit (ESP32 included) | |
| 1 | × | DIYables ESP32 S3 Starter Kit (ESP32 S3 included) | |
| 1 | × | DIYables Sensor Kit (18 sensors/displays) |
Additionally, some of these links are for products from our own brand, DIYables .
For Part 1 you need only one motor. The second motor is for Part 2.
Overview of DRV8833 Motor Driver
A GPIO pin of the ESP32 gives only a few milliamps at 3.3 volts. A DC motor wants hundreds of milliamps, and it also wants the current to flip when you change direction. The DRV8833 does this job for you. It is a small chip from Texas Instruments with two H-bridges inside, so one module can run two brushed DC motors on its own (or one bipolar stepper motor, but that is not part of this guide).
Why pick it for an ESP32 project? Its outputs are MOSFETs with a low resistance (about 360 mΩ for the high side and low side together). Much less power turns into heat, and the motor gets almost the full battery voltage. This makes it a good fit for small robots that run on 3 volts to 9 volts batteries. The chip makes its own logic voltage inside, so the 3.3 volts signals from the ESP32 work directly. You do not need a level shifter or a second supply.
| Item | DRV8833 value |
|---|---|
| Motor supply (VCC pin) | 2.7V to 10.8V |
| Number of channels | 2 (motor A and motor B) |
| Current per channel | about 1.5A RMS, 2A peak (with good cooling) |
| Two channels joined together | about 3A (optional) |
| Control logic | 3.3V and 5V both work |
| PWM frequency | up to 50 kHz |
| Protection | under-voltage lockout, over-current, thermal shutdown |
The DRV8833 has no ENA/ENB pins like the L298N. To set the speed, you send PWM straight into the IN pins. Because of this, both IN pins of a channel must be on PWM-capable GPIOs. Nearly every output GPIO of the ESP32 can do PWM, so this is easy.
Pinout
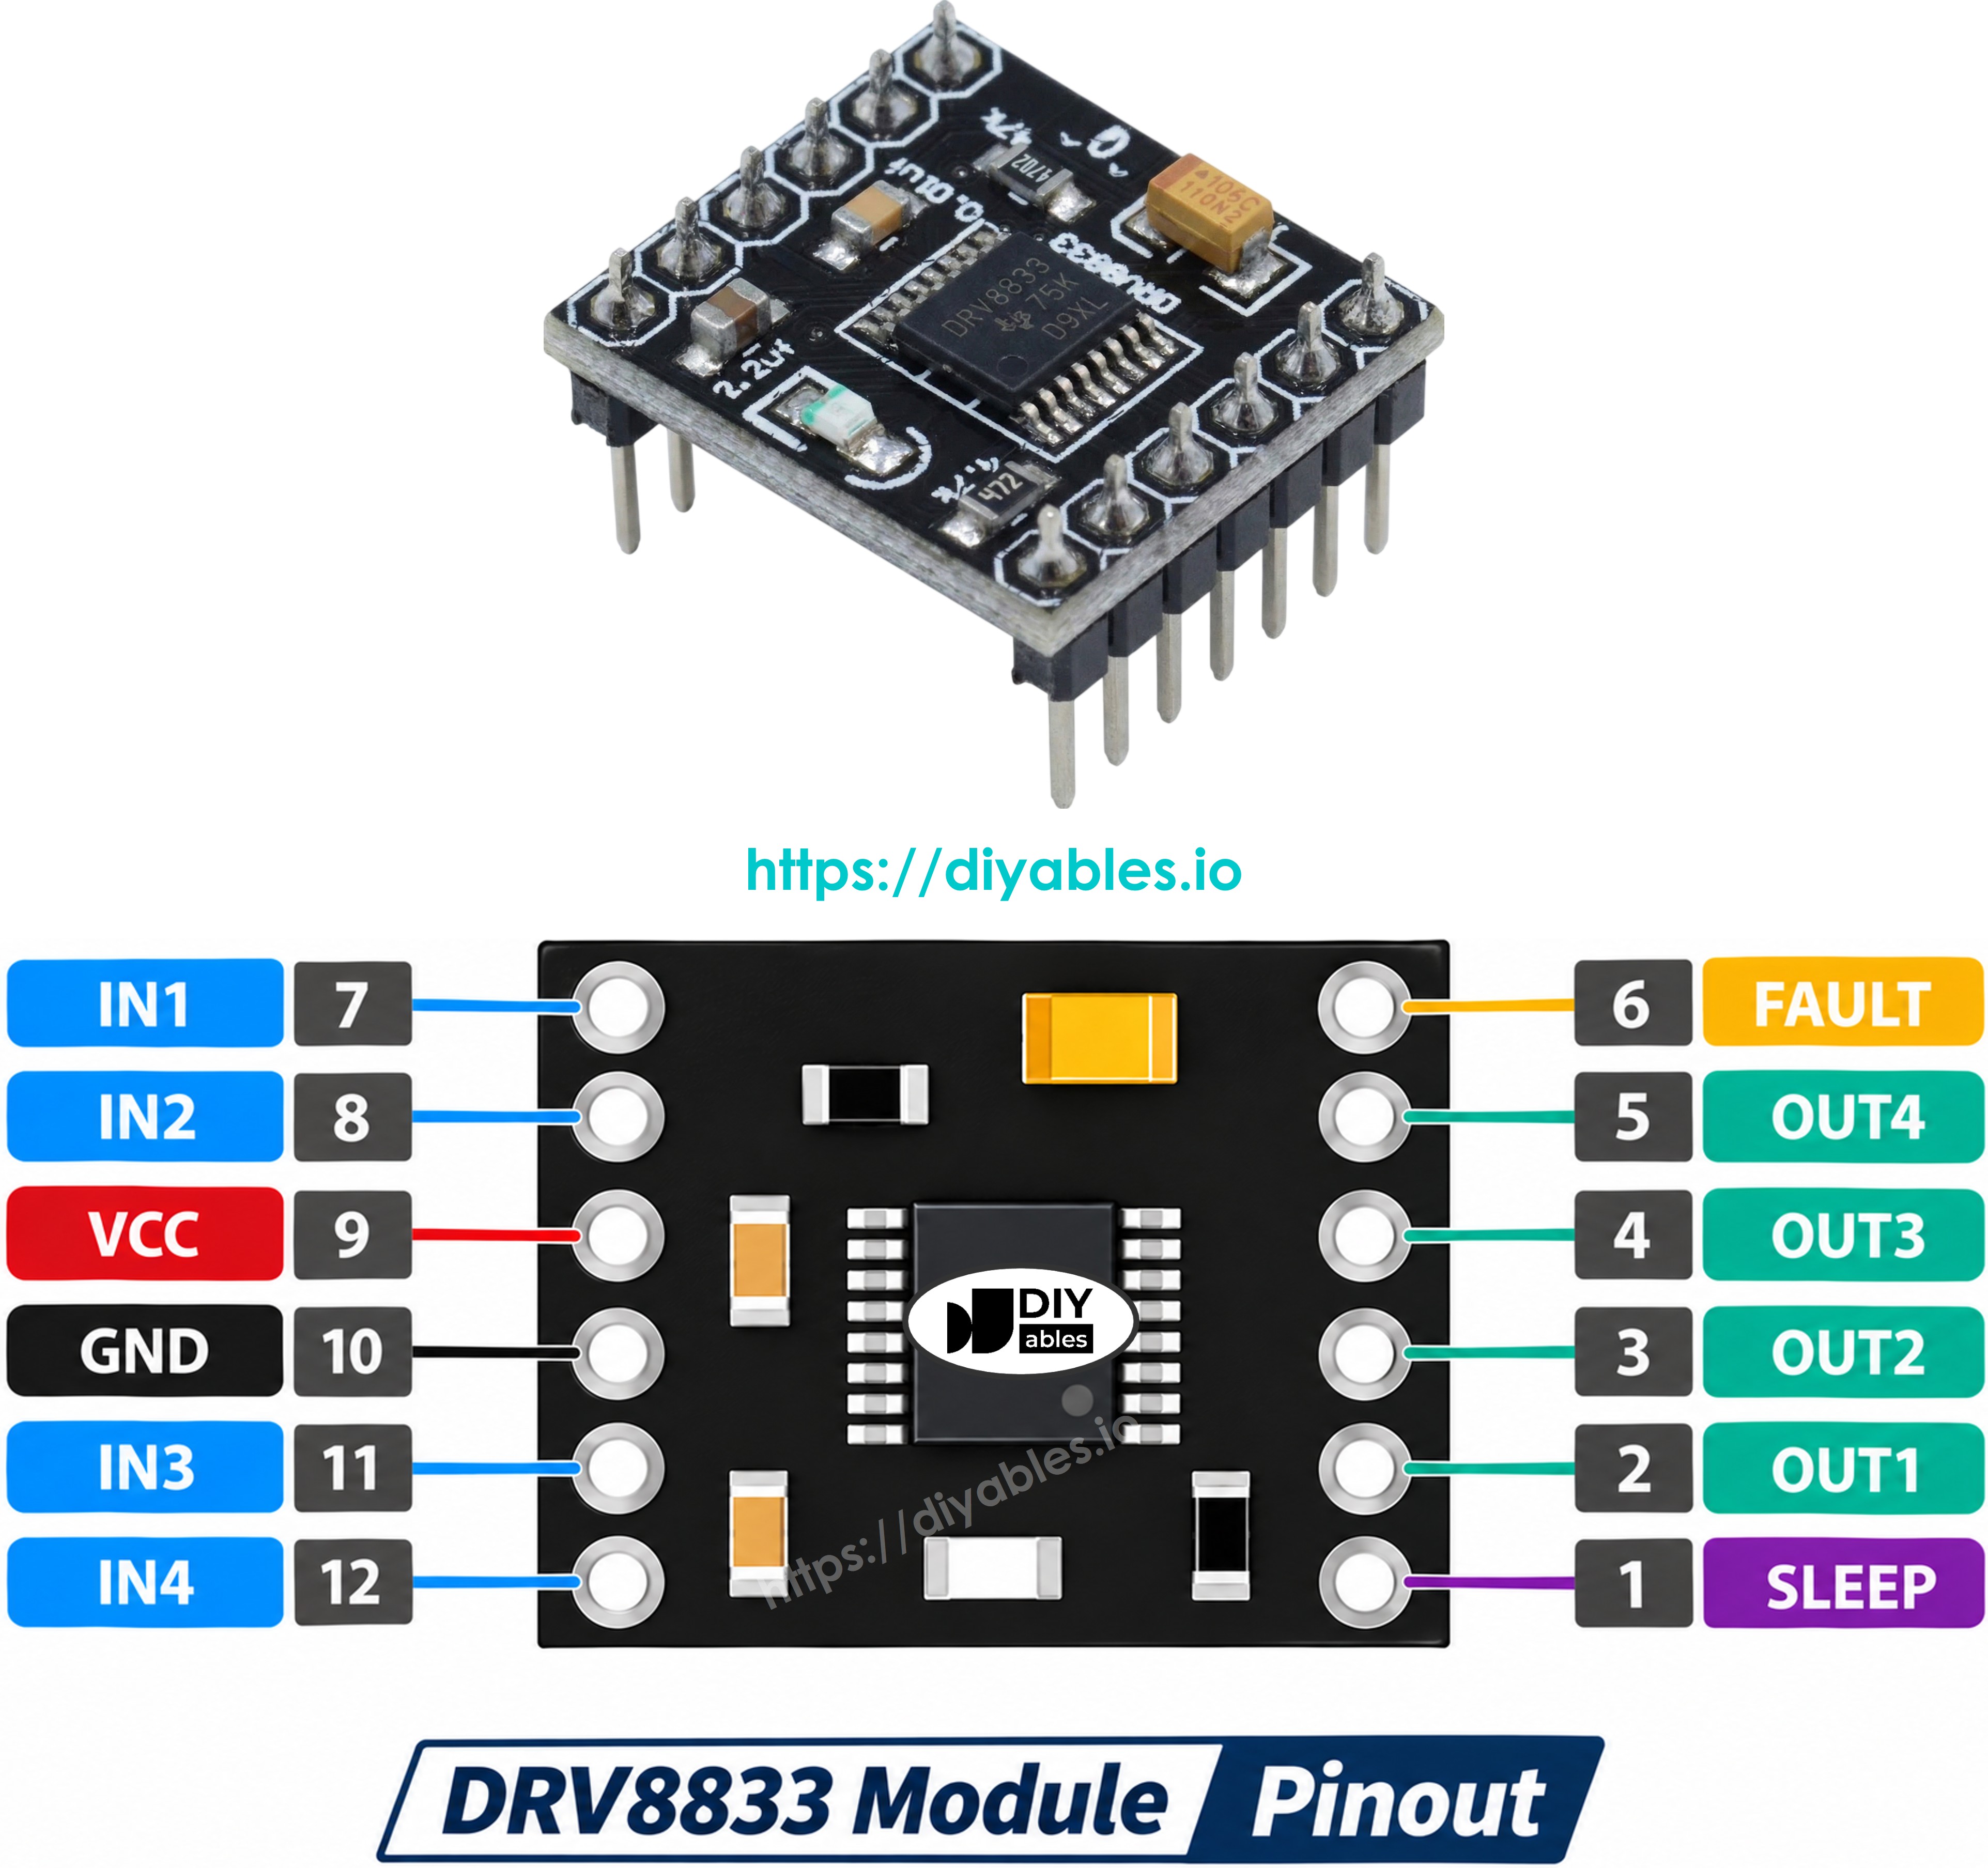
The pin labels are not the same on every board. Some modules print AIN1/AIN2/BIN1/BIN2, AOUT1/AOUT2/BOUT1/BOUT2, SLP and FLT instead of the names below. The job of each pin is the same.
- IN1 and IN2 pins: control motor A. Connect to two PWM GPIO pins of the ESP32.
- IN3 and IN4 pins: control motor B. Connect to two more PWM GPIO pins of the ESP32.
- OUT1 and OUT2 pins: connect to the two wires of motor A.
- OUT3 and OUT4 pins: connect to the two wires of motor B.
- VCC pin: connect to the motor power supply (2.7 volts to 10.8 volts). It is not a logic supply pin.
- GND pin: connect to GND (0 volts) of the motor supply AND to GND of the ESP32.
- EEP pin (sleep, also called nSLEEP or SLP): connect to 3.3 volts of the ESP32 to keep the driver awake. If it is LOW, the chip sleeps and the motors do nothing.
- ULT pin (fault, also called nFAULT or FLT): goes LOW when the chip finds a problem, such as overheating or too much current. You can leave it unconnected.
How the IN Pins Control a Motor
Each channel looks at its two IN pins. The table is for motor A. Motor B works the same way with IN3 and IN4.
| IN1 | IN2 | What motor A does |
|---|---|---|
| LOW | LOW | Coast - the power is cut and the motor rolls slowly to a stop |
| PWM (or HIGH) | LOW | Forward - higher duty means faster |
| LOW | PWM (or HIGH) | Reverse - higher duty means faster |
| HIGH | HIGH | Brake - the motor stops quickly |
In MicroPython, duty_u16() takes a value from 0 to 65535. So duty_u16(65535) means HIGH, duty_u16(0) means LOW, and a value in between sets the speed. The code in this tutorial uses a percent from -100 to 100 instead. A plus sign means forward, a minus sign means reverse, and the code turns the percent into a duty value for you.
Power rules to remember:
- The motors take power from an external supply, such as a 5 volts adapter through a DC power jack, or a 4 x AA battery pack (about 6 volts). Never take motor power from the 3.3V or 5V pin of the ESP32.
- The GND of the supply, the GND of the DRV8833 and the GND of the ESP32 must all be connected together. Without a common ground, the IN signals have no reference and the motor acts strangely.
Part 1 - Control One DC Motor with ESP32 MicroPython
We start with only motor A on channel A. Channel B stays empty for now.
Wiring Diagram
- Option 1: wire the ESP32 to the DRV8833 directly with jumper wires
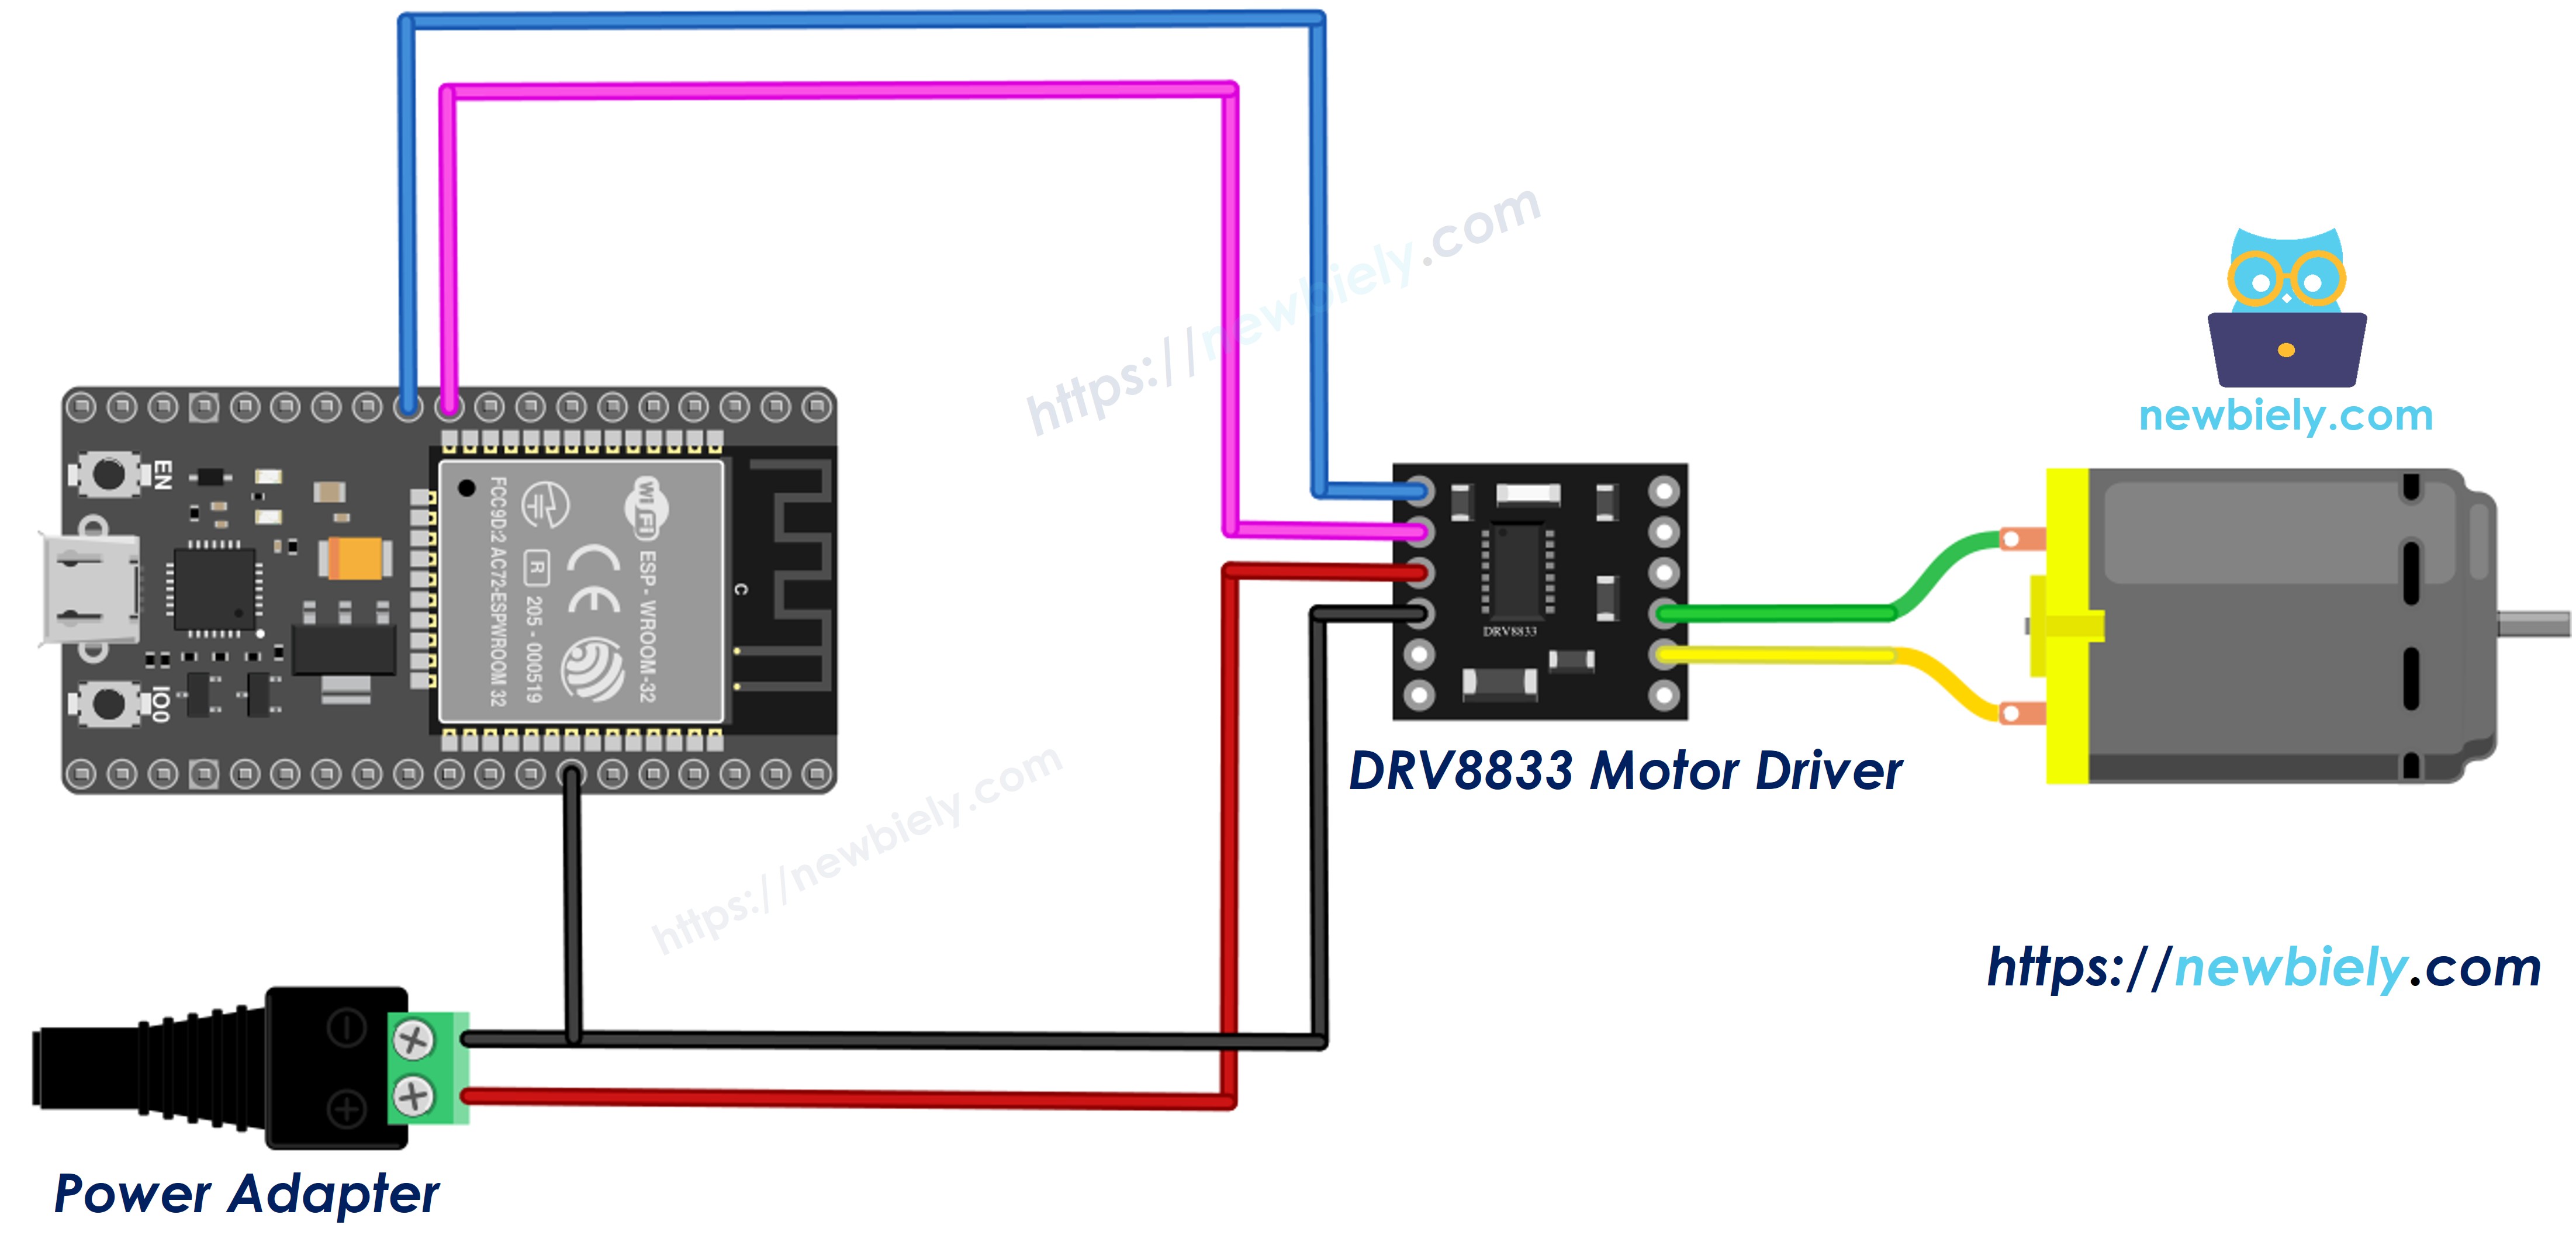
This image is created using Fritzing. Click to enlarge image
- Option 2: use a screw terminal block breakout board for firmer connections
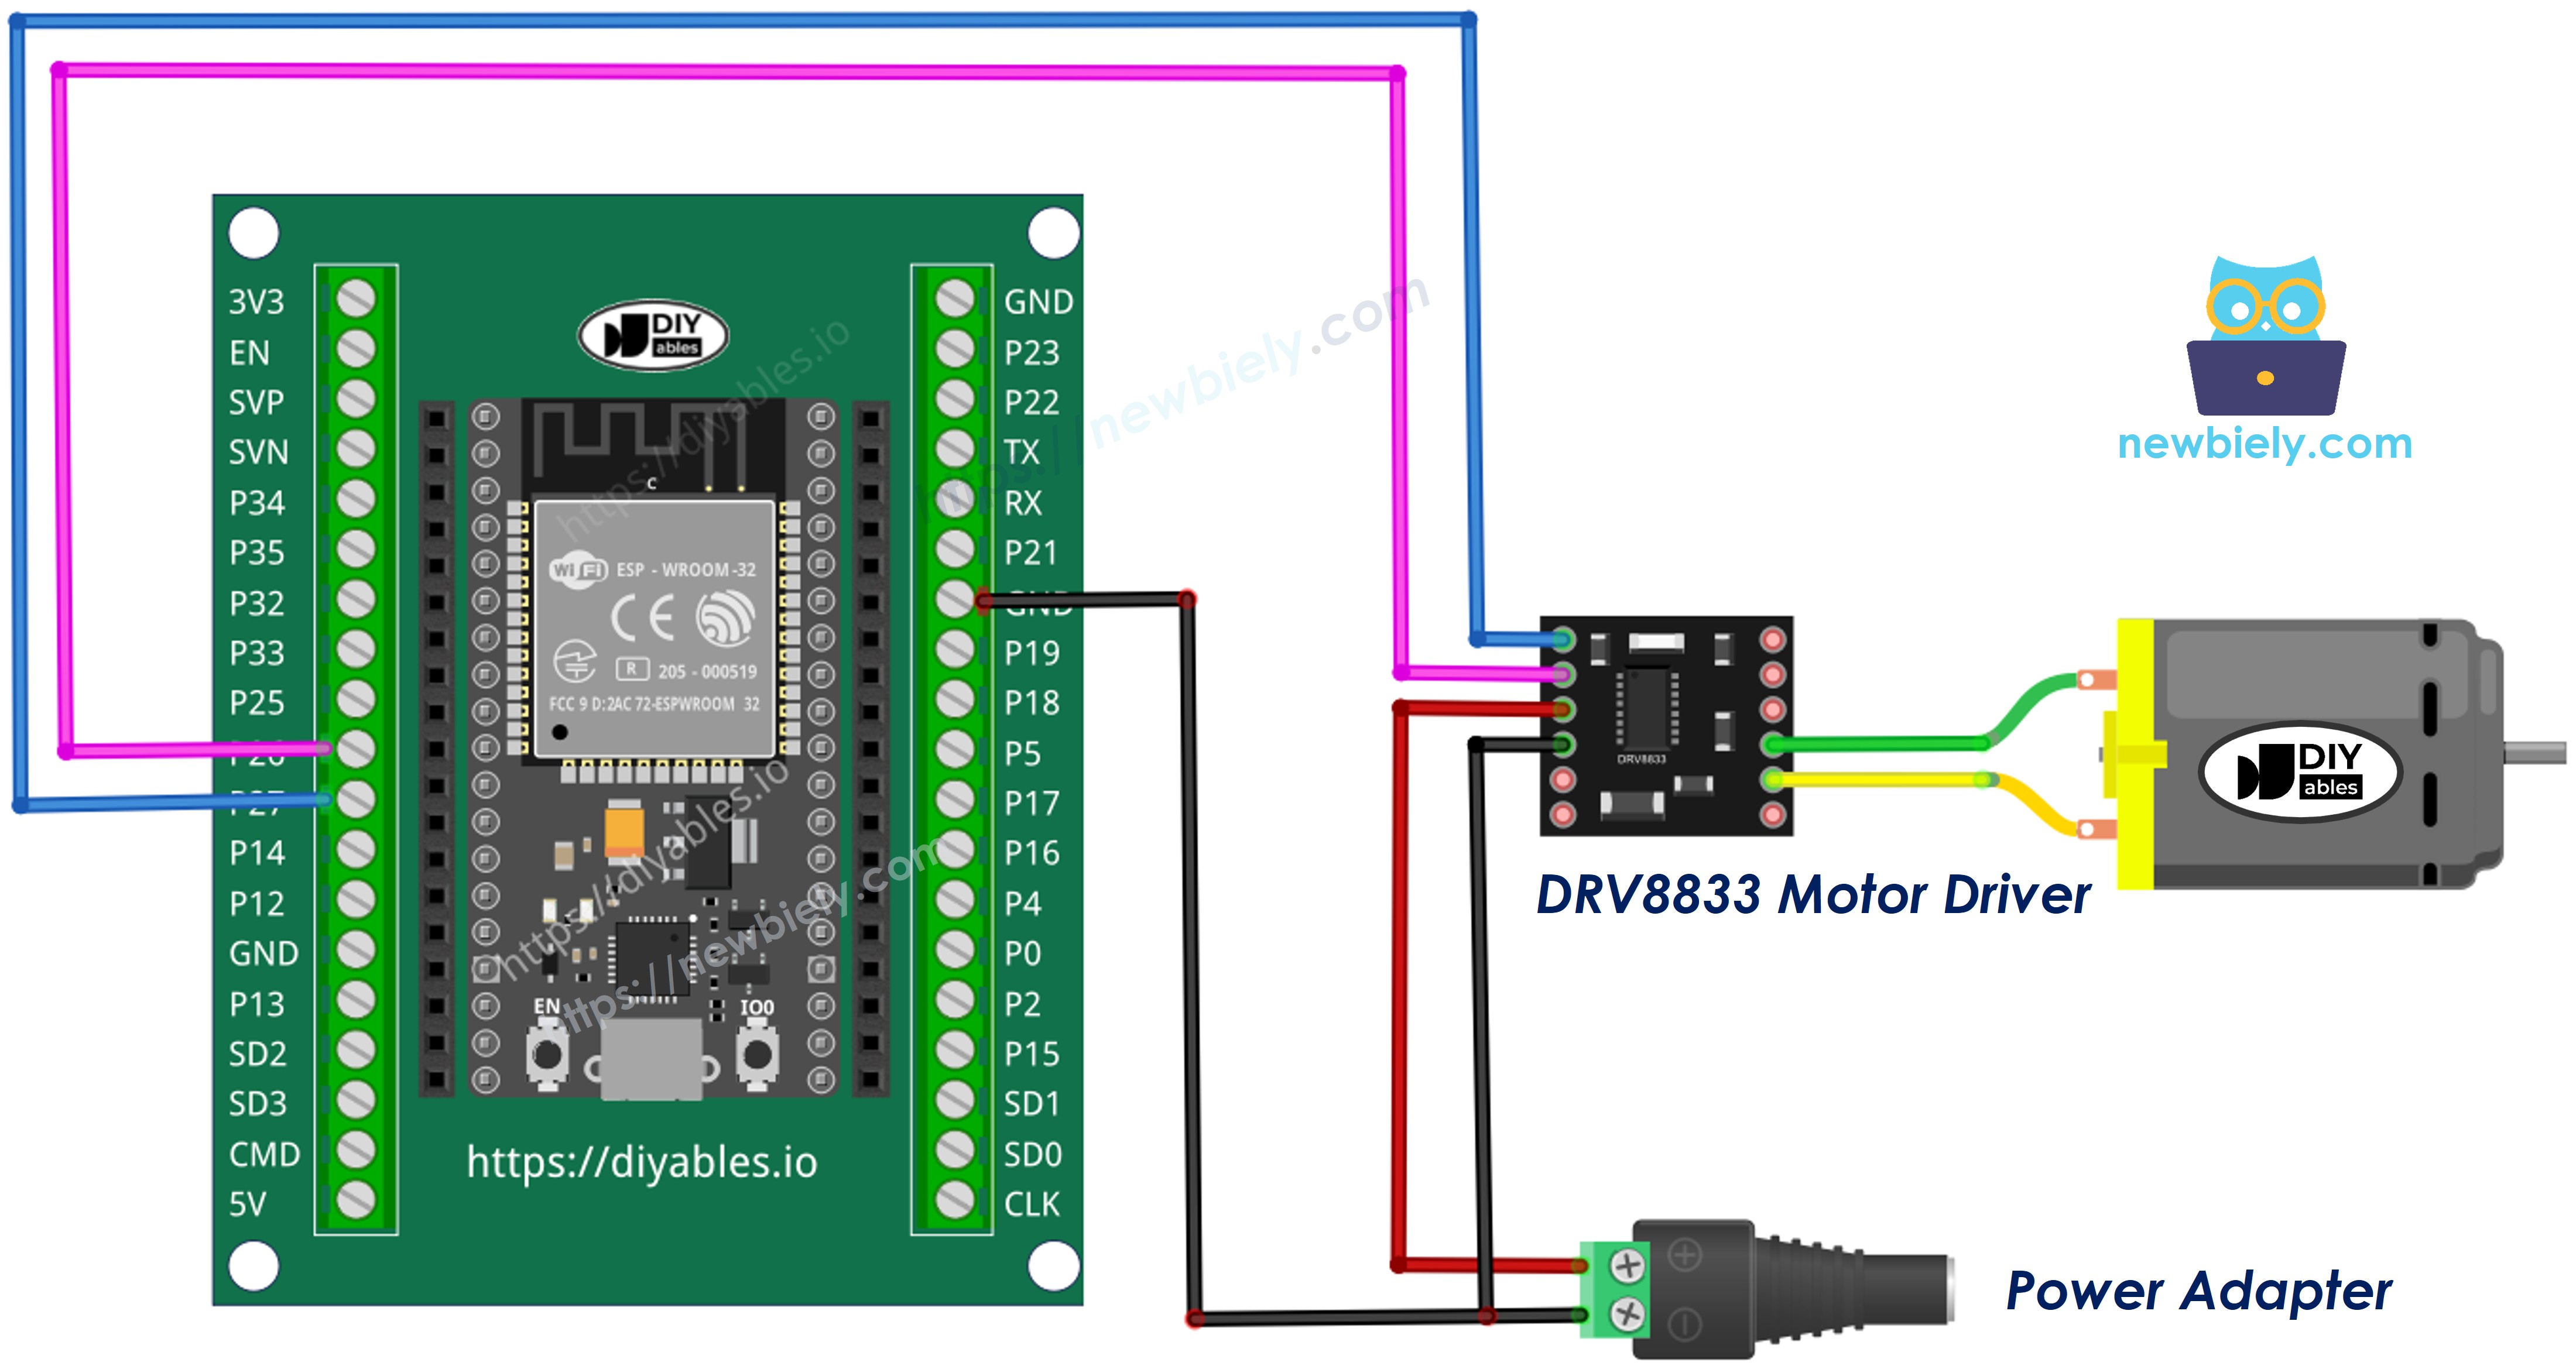
This image is created using Fritzing. Click to enlarge image
| DRV8833 Pin | Connect To |
|---|---|
| IN1 | ESP32 GPIO27 |
| IN2 | ESP32 GPIO26 |
| EEP | ESP32 3.3V |
| GND | ESP32 GND and 5V adapter − (through the DC power jack) |
| VCC | 5V adapter + (through the DC power jack) |
| OUT1 | Motor A wire 1 |
| OUT2 | Motor A wire 2 |
| ULT | not connected |
If the motor turns the wrong way, swap the two motor wires on OUT1 and OUT2. You do not need to change the code.
ESP32 MicroPython Code - One DC Motor
No library is needed. The script uses machine.PWM, which is part of MicroPython. GPIO27 and GPIO26 both become 1 kHz PWM outputs. The motor_a() function takes a speed from -100 to 100 and sets the two IN pins as shown in the table above. The motor_a_brake() function sets both pins HIGH.
Each loop goes like this: the motor speeds up forward in 20% steps, runs at full speed for 2 seconds, coasts for 2 seconds, turns in reverse at 60% for 2 seconds, and then brakes hard. Every step is printed to the Shell.
Detailed Instructions
Here's instructions on how to set up and run your MicroPython code on the ESP32 using Thonny IDE:
- Make sure Thonny IDE is installed on your computer.
- Confirm that MicroPython firmware is loaded on your ESP32 board.
- New to MicroPython on the ESP32? Read the ESP32 MicroPython Getting Started guide first.
- Wire the ESP32, the DRV8833 module, the motor and the DC power jack as shown in the diagram. Keep the 5V adapter unplugged for now.
- Connect the ESP32 board to your computer with a USB cable.
- Open Thonny IDE on your computer.
- In Thonny, go to Tools Options, open the Interpreter tab, and choose MicroPython (ESP32) from the dropdown.
- Copy the provided MicroPython code and paste it into Thonny's editor.
- Save the code to your ESP32 by:
- Clicking the Save button or pressing Ctrl+S.
- Choosing MicroPython device in the save dialog.
- Typing main.py as the file name.
- Plug the 5V adapter into the DC power jack.
- Click the green Run button (or press F5) to execute the script.
- Watch the motor. You can feel the difference between coast and brake: after coast the shaft keeps turning for a moment, after brake it stops almost at once.
- Check out the message in the Shell at the bottom of Thonny.
A small motor may not move at 20%. That is normal: the duty is too low to beat the friction inside the motor. It starts to turn once the duty goes a bit higher.
Part 2 - Control Two DC Motors with ESP32 MicroPython
Now we use channel B too. Think of motor A as the left wheel and motor B as the right wheel of a small robot car. To turn, one wheel goes forward and the other goes back, so the car spins in place.
Wiring Diagram
- Option 1: wire the ESP32 to the DRV8833 directly with jumper wires
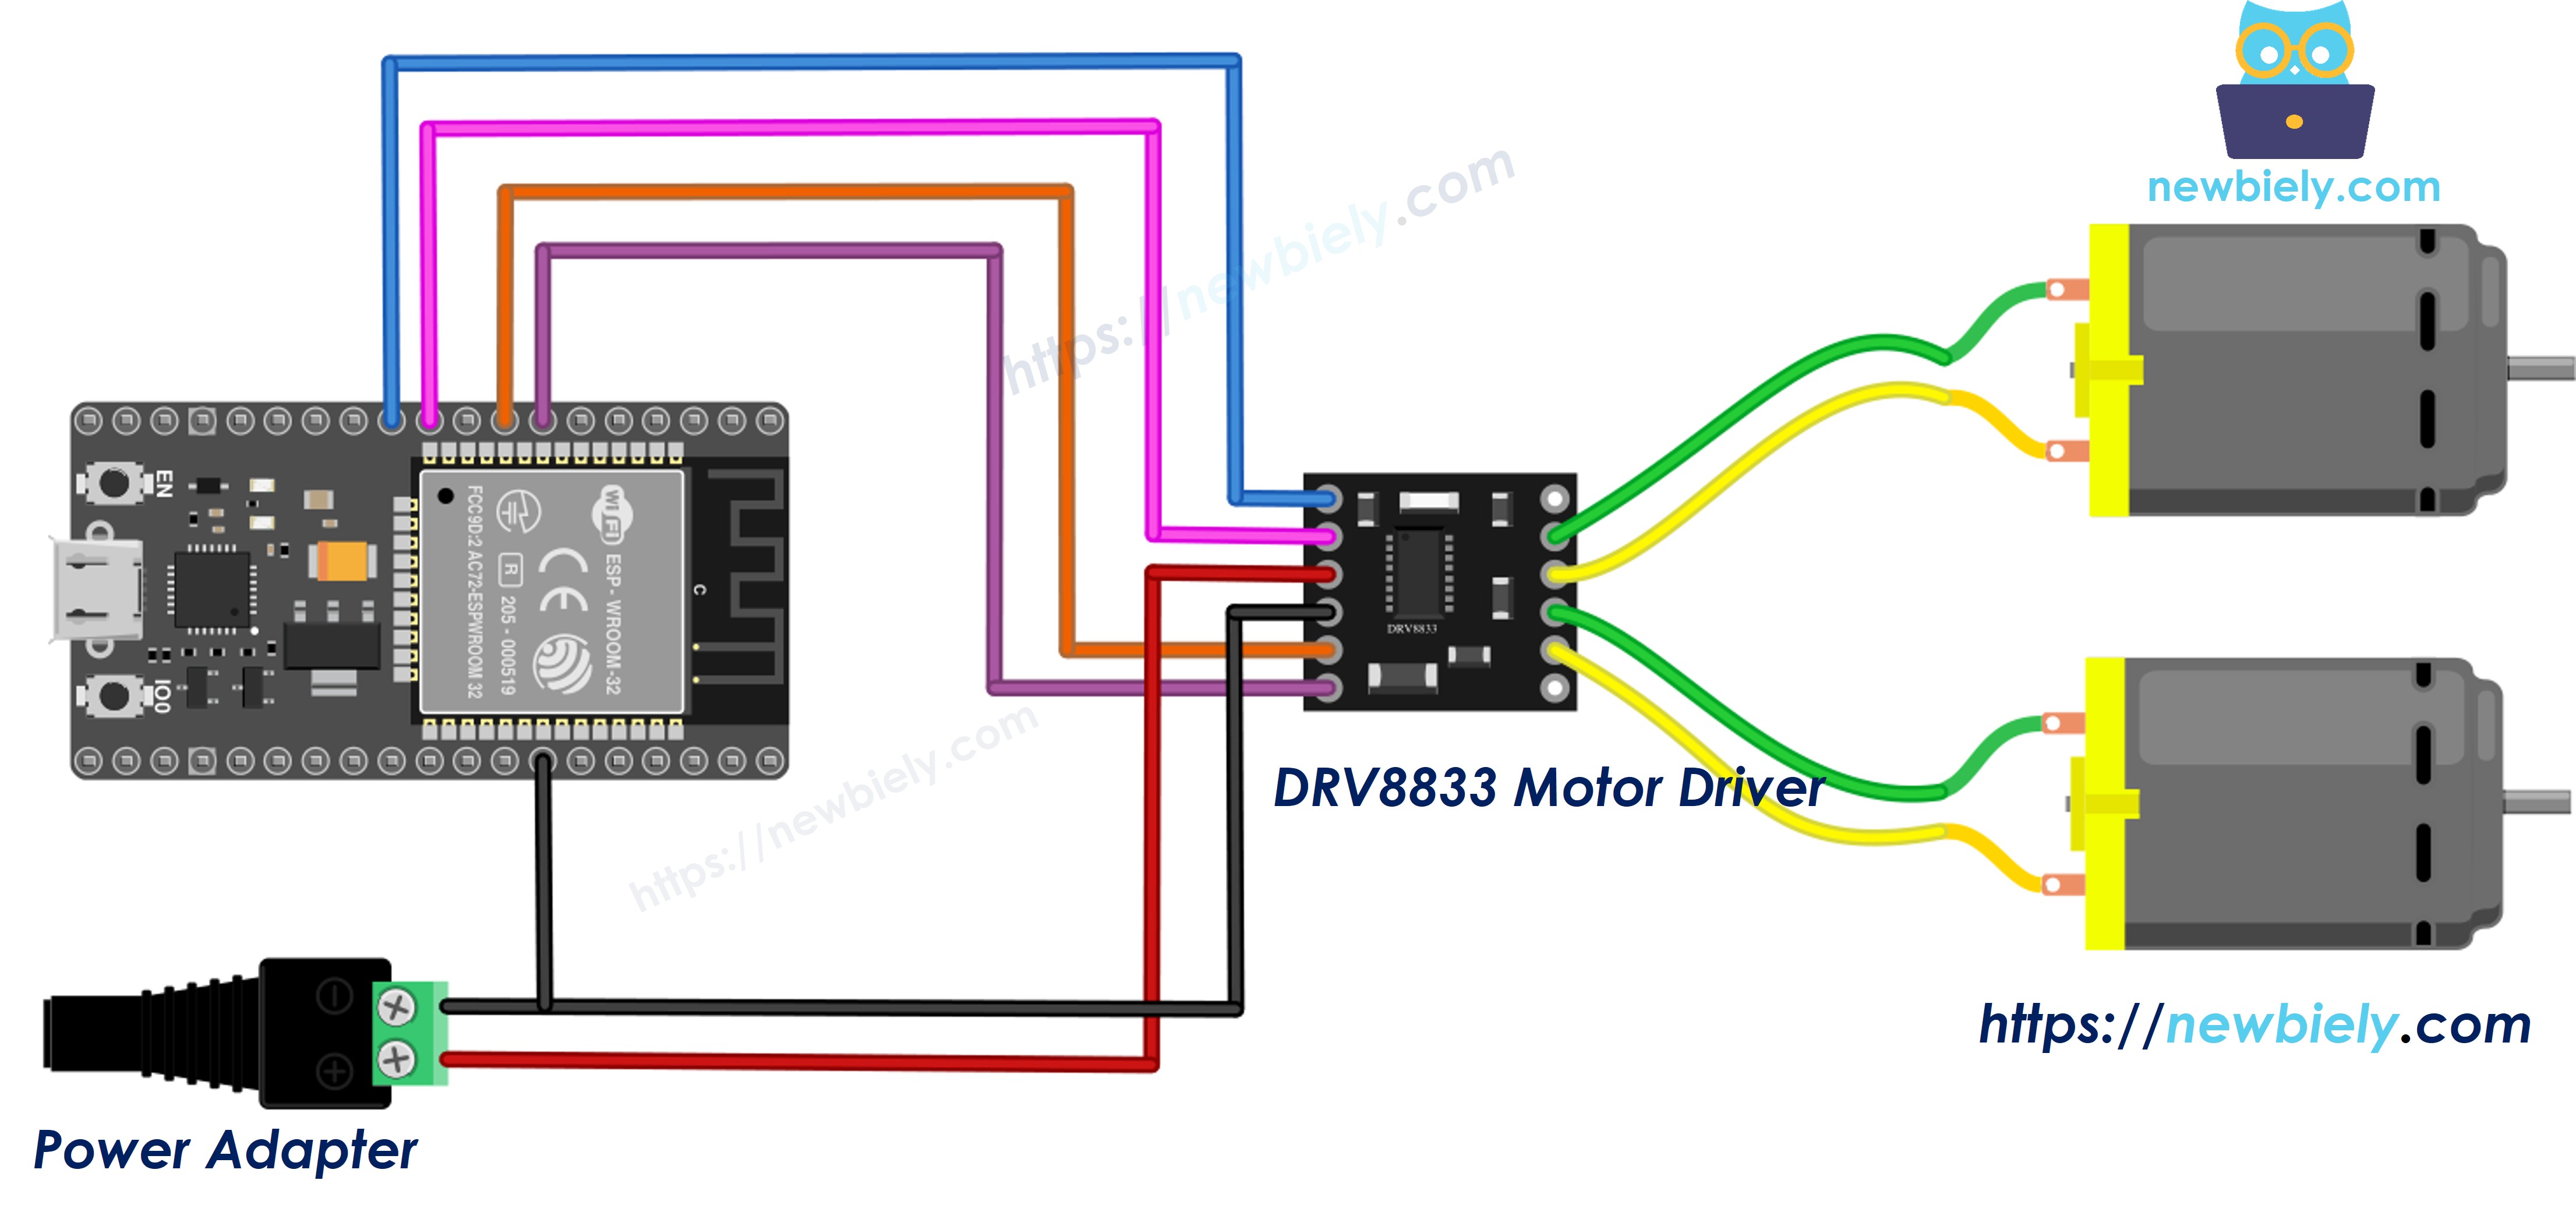
This image is created using Fritzing. Click to enlarge image
- Option 2: use a screw terminal block breakout board for firmer connections
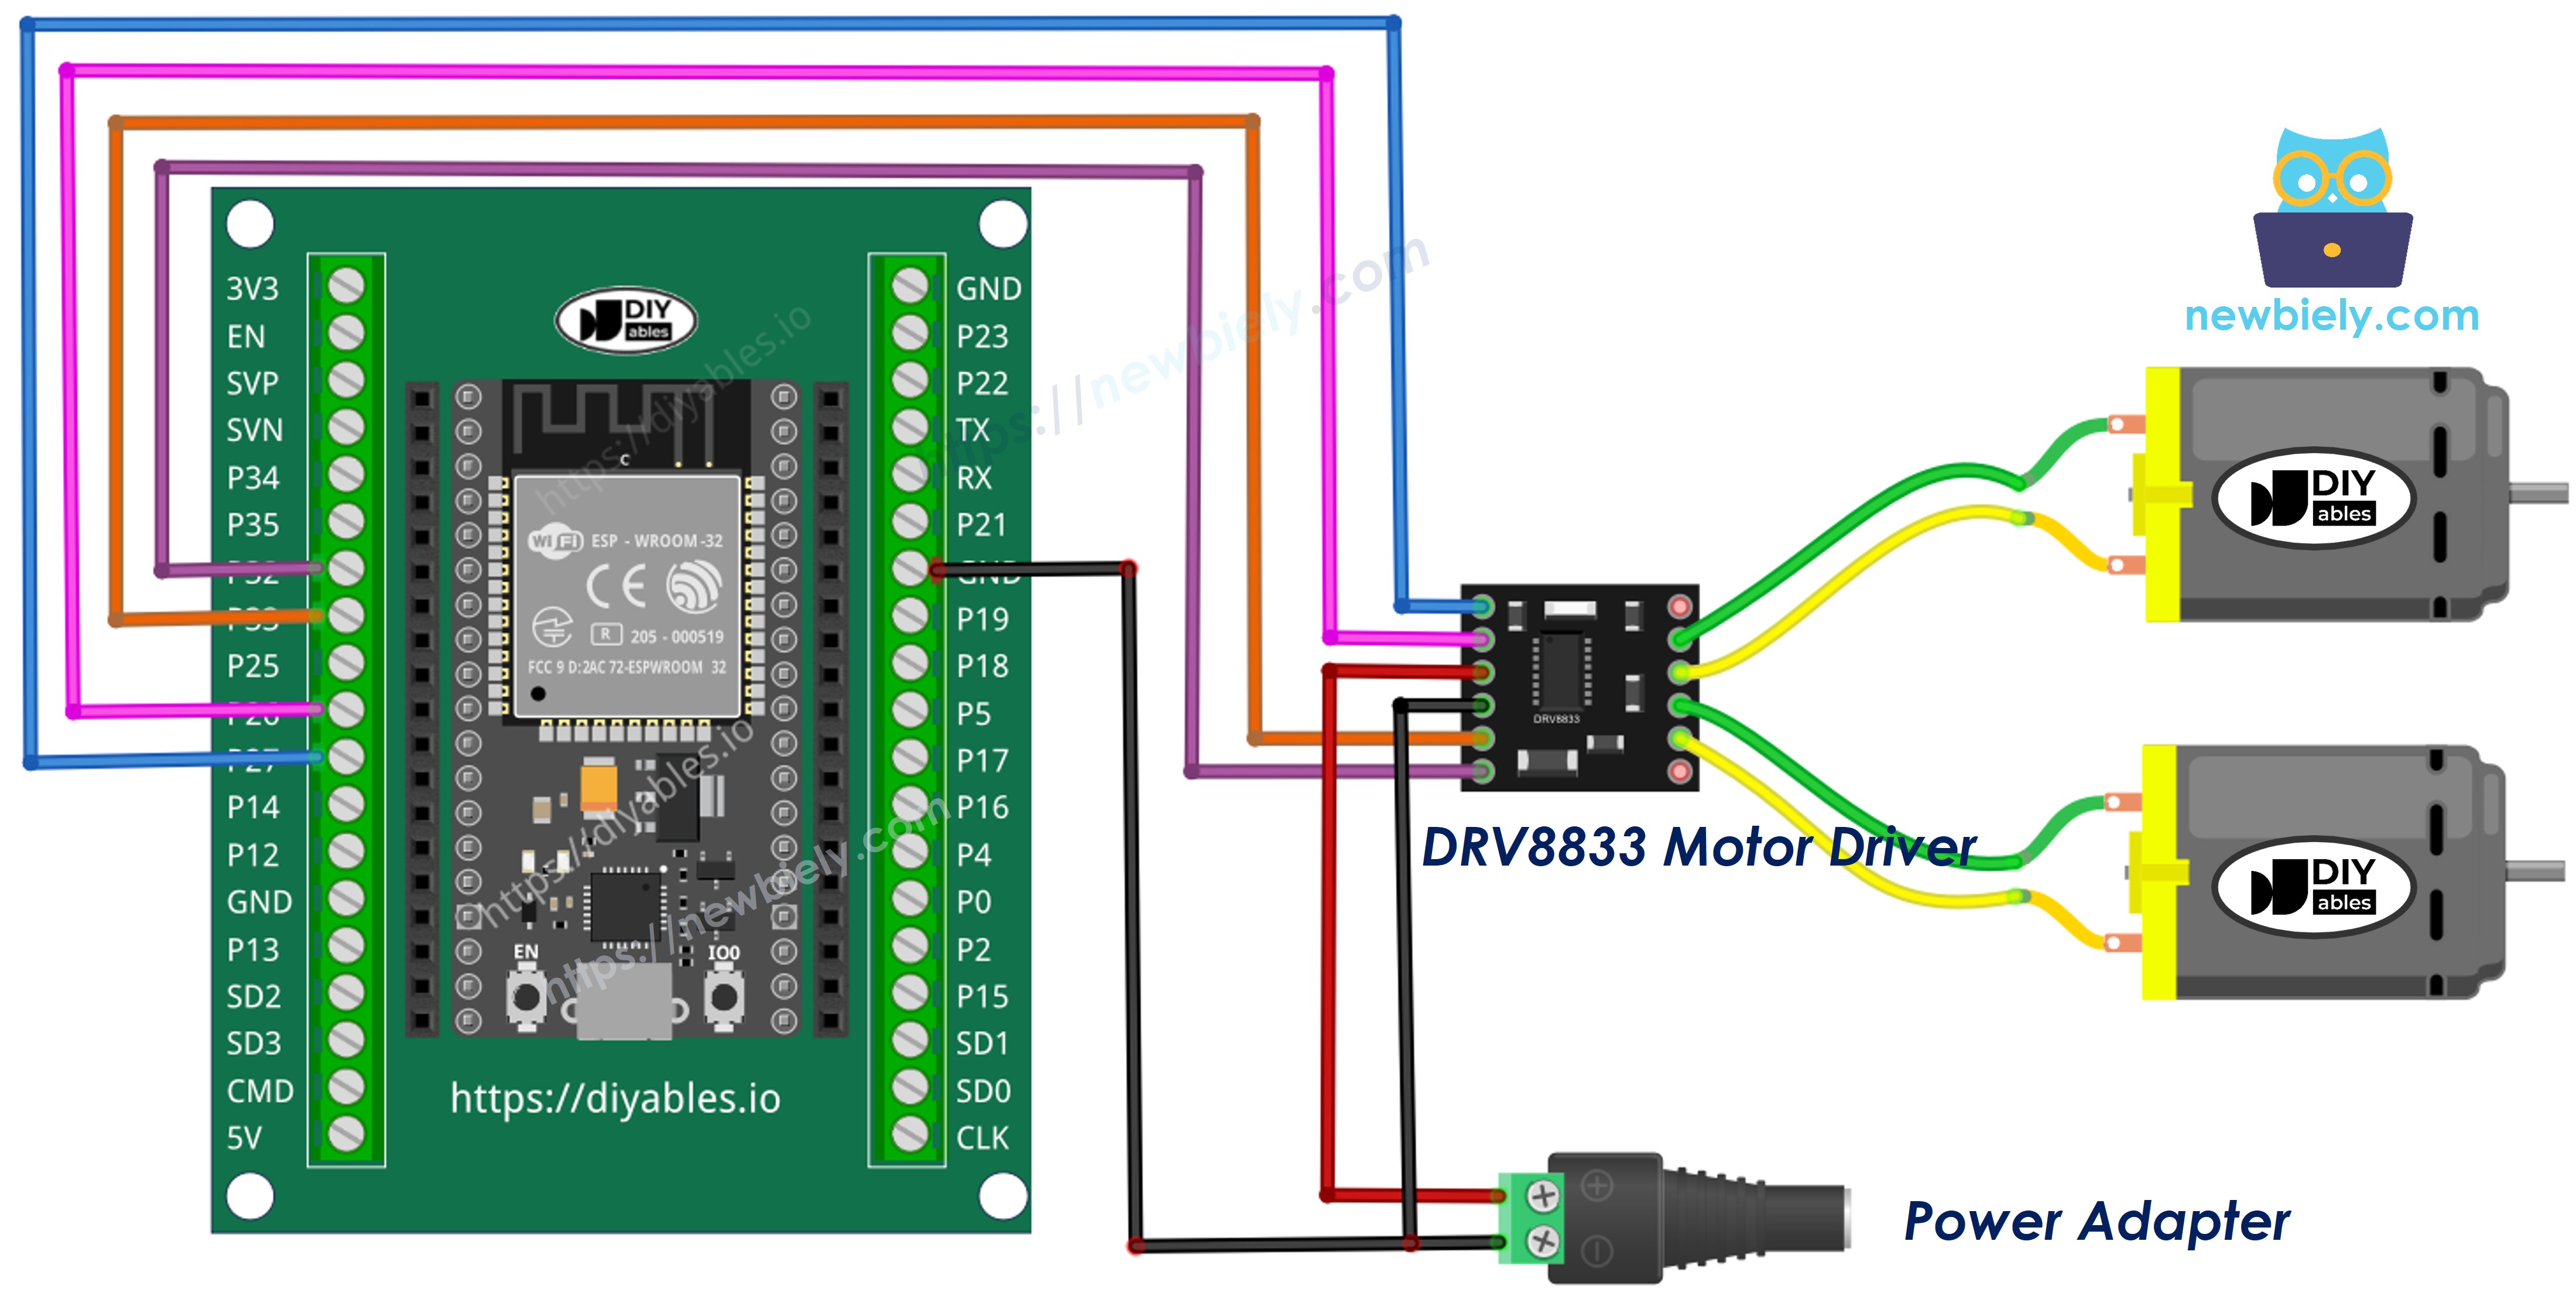
This image is created using Fritzing. Click to enlarge image
| DRV8833 Pin | Connect To |
|---|---|
| IN1 | ESP32 GPIO27 |
| IN2 | ESP32 GPIO26 |
| IN3 | ESP32 GPIO33 |
| IN4 | ESP32 GPIO32 |
| EEP | ESP32 3.3V |
| GND | ESP32 GND and 5V adapter − (through the DC power jack) |
| VCC | 5V adapter + (through the DC power jack) |
| OUT1, OUT2 | Motor A (left wheel) |
| OUT3, OUT4 | Motor B (right wheel) |
Two motors pull more current than one. A small 5 volts adapter rated 2A or more is a safe choice. If one wheel turns the wrong way, swap the wires of that motor only.
ESP32 MicroPython Code - Two DC Motors
This script adds GPIO33 and GPIO32 for channel B. One shared function, set_channel(), handles any channel, and motor_a() and motor_b() call it with their own pins. On top of these, there are five easy driving functions: forward(), backward(), turn_left(), turn_right() and stop(). The speed for all of them is set in one place, DRIVE_SPEED = 70.
Detailed Instructions
- Add the second motor and the IN3/IN4 wires as shown in the new diagram.
- Copy the code above, paste it into Thonny, and save it to the ESP32 as main.py (replace the old file).
- Plug in the 5V adapter, then click the green Run button.
- Lift the car (or hold the motors) so the wheels can spin freely while you test.
- Check out the message in the Shell at the bottom of Thonny.
If you name your script main.py and save it to the MicroPython device, it will run automatically every time the ESP32 is powered on.
The motors stop by themselves in the middle of a run? The DRV8833 may be too hot, or the current may be too high, so its protection cut the power. Let it cool down, use smaller motors, or lower DRIVE_SPEED.