
ESP32 C3 Super Mini - 28BYJ-48 Stepper Motor ULN2003 Driver
Learn how to control the 28BYJ-48 stepper motor using the ESP32 C3 Super Mini and ULN2003 driver module for precise position control in your Arduino projects. This tutorial shows you how to wire, program, and control one or multiple stepper motors with simple code examples.
In this ESP32 C3 Super Mini stepper motor tutorial, you'll learn:
- What the 28BYJ-48 stepper motor is and why it's perfect for beginners
- How to wire the stepper motor to ESP32 C3 Super Mini using the ULN2003 driver
- How to write code to control stepper motor rotation and direction
- How to control multiple stepper motors simultaneously
- How to use the AccelStepper library for smooth motor control
Why use stepper motors with ESP32 C3 Super Mini:
- Excellent for precision position control in robotics and automation
- Break down full rotation into discrete steps for accurate movement
- Commonly used in 3D printers, CNC machines, and industrial systems
- The 28BYJ-48 is affordable and beginner-friendly
- ULN2003 driver makes wiring and control simple
Hardware Preparation
Or you can buy the following kits:
| 1 | × | DIYables Sensor Kit (18 sensors/displays) |
Additionally, some of these links are for products from our own brand, DIYables .
Overview of 28BYJ-48 Stepper Motor
The 28BYJ-48 is a small unipolar stepper motor that provides precise position control through stepped rotation.
Key specifications of the 28BYJ-48 stepper motor:
- Step angle: 11.25 degrees in full-step mode (32 steps per revolution)
- Gear ratio: 1/64 reduction gear set included
- Total steps: 2048 steps per full revolution (32 × 64)
- Step precision: Approximately 0.1758 degrees per step (360°/2048)
- Operating voltage: 5V DC
- Interface: 5-pin connector that plugs directly into ULN2003 driver
- Torque: Low to medium torque suitable for light applications
- Cost: Very affordable for beginners learning stepper motor control
Important: When using the 28BYJ-48 stepper motor in full-step mode, it requires 2048 steps to complete one full revolution.
28BYJ-48 Stepper Motor Pinout
The 28BYJ-48 stepper motor has 5 pins on its connector.
- Pin 1-5: Internal motor coil connections
- Connector: Male 5-pin connector that plugs into ULN2003 driver
Note: You don't need to worry about individual pin connections - simply plug the motor's connector directly into the ULN2003 driver module's socket.
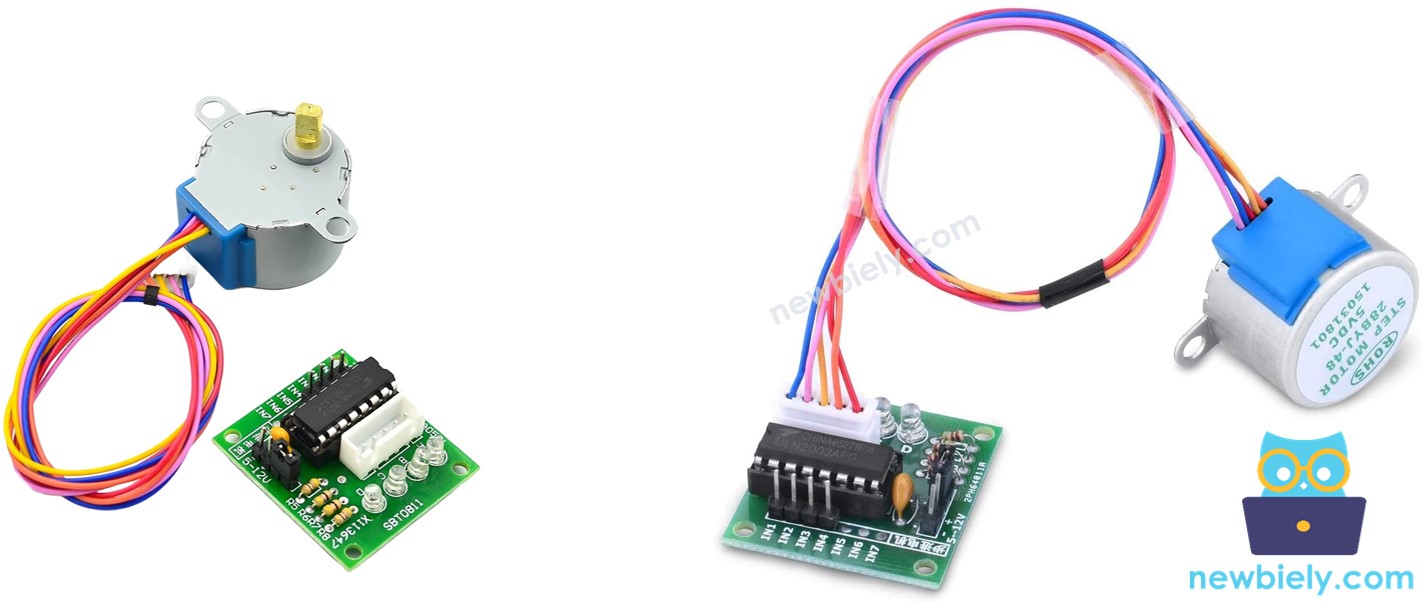
Overview of ULN2003 Stepper Motor Driver Module
The ULN2003 is a popular and easy-to-use driver module specifically designed for controlling stepper motors with Arduino and ESP32 boards.
Key features of the ULN2003 driver module:
- 4 control inputs: IN1, IN2, IN3, IN4 for motor control signals
- LED indicators: Four onboard LEDs show real-time stepping activity
- Power control: ON/OFF jumper for easy motor power management
- Power supply: Separate power input (5V-12V) for the stepper motor
- Easy wiring: Direct plug-in connector for 28BYJ-48 motor
- Protection: Built-in protection for your microcontroller
- Beginner-friendly: Simple to wire and program
ULN2003 Driver Pinout
The ULN2003 module has 6 pins and one female connector for easy stepper motor control.
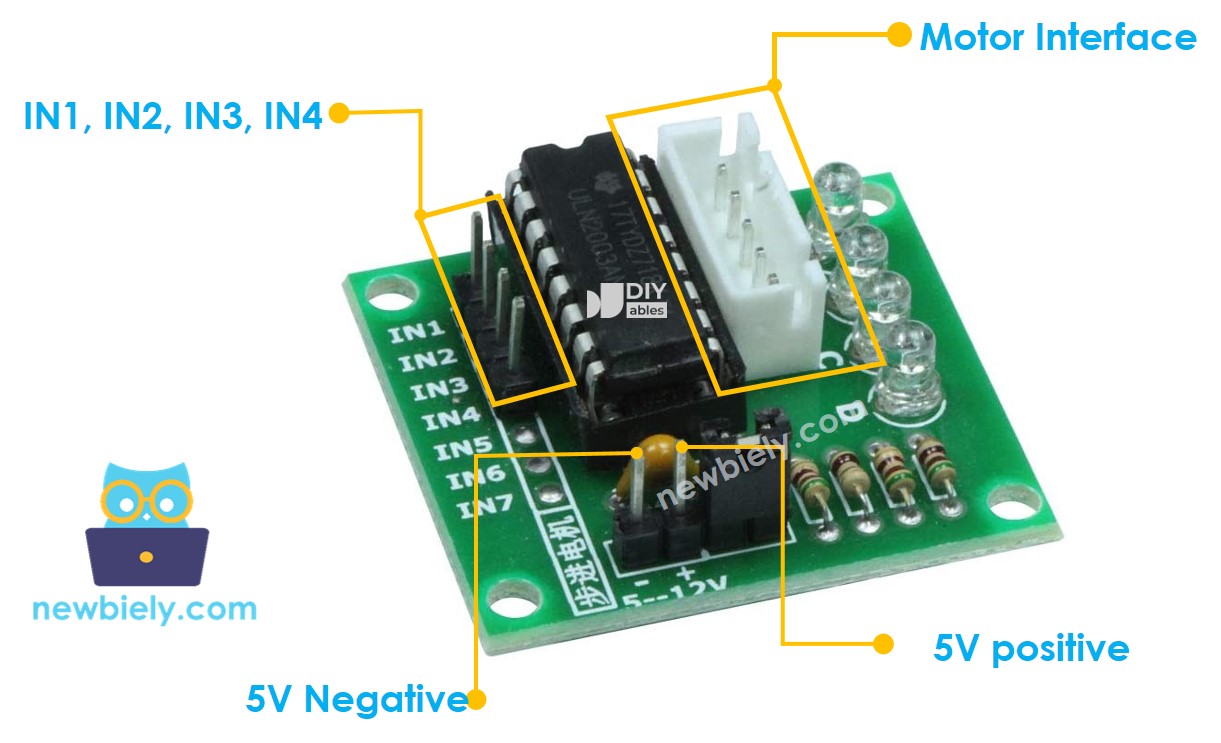
- IN1: Control input pin 1 - connects to ESP32 C3 Super Mini digital pin
- IN2: Control input pin 2 - connects to ESP32 C3 Super Mini digital pin
- IN3: Control input pin 3 - connects to ESP32 C3 Super Mini digital pin
- IN4: Control input pin 4 - connects to ESP32 C3 Super Mini digital pin
- GND: Ground pin - MUST connect to both ESP32 and external power supply ground
- VDD: Motor power supply input - connects to external 5V power source
- Motor Connector: Female socket where the 28BYJ-48 motor plugs in
※ NOTE THAT:
Important power supply notes for stepper motor operation:
- Always match the external power supply voltage to your motor's specifications
- The 28BYJ-48 stepper motor requires 5V DC external power supply
- Never connect the VDD pin to the ESP32 C3 Super Mini's 5V pin
- Stepper motors draw high current that can damage your ESP32
- Always use a dedicated external power supply for the motor
- Connect all grounds together (ESP32 GND, driver GND, power supply GND)
Wiring Diagram
This diagram shows how to connect the 28BYJ-48 stepper motor to the ESP32 C3 Super Mini using the ULN2003 driver module.
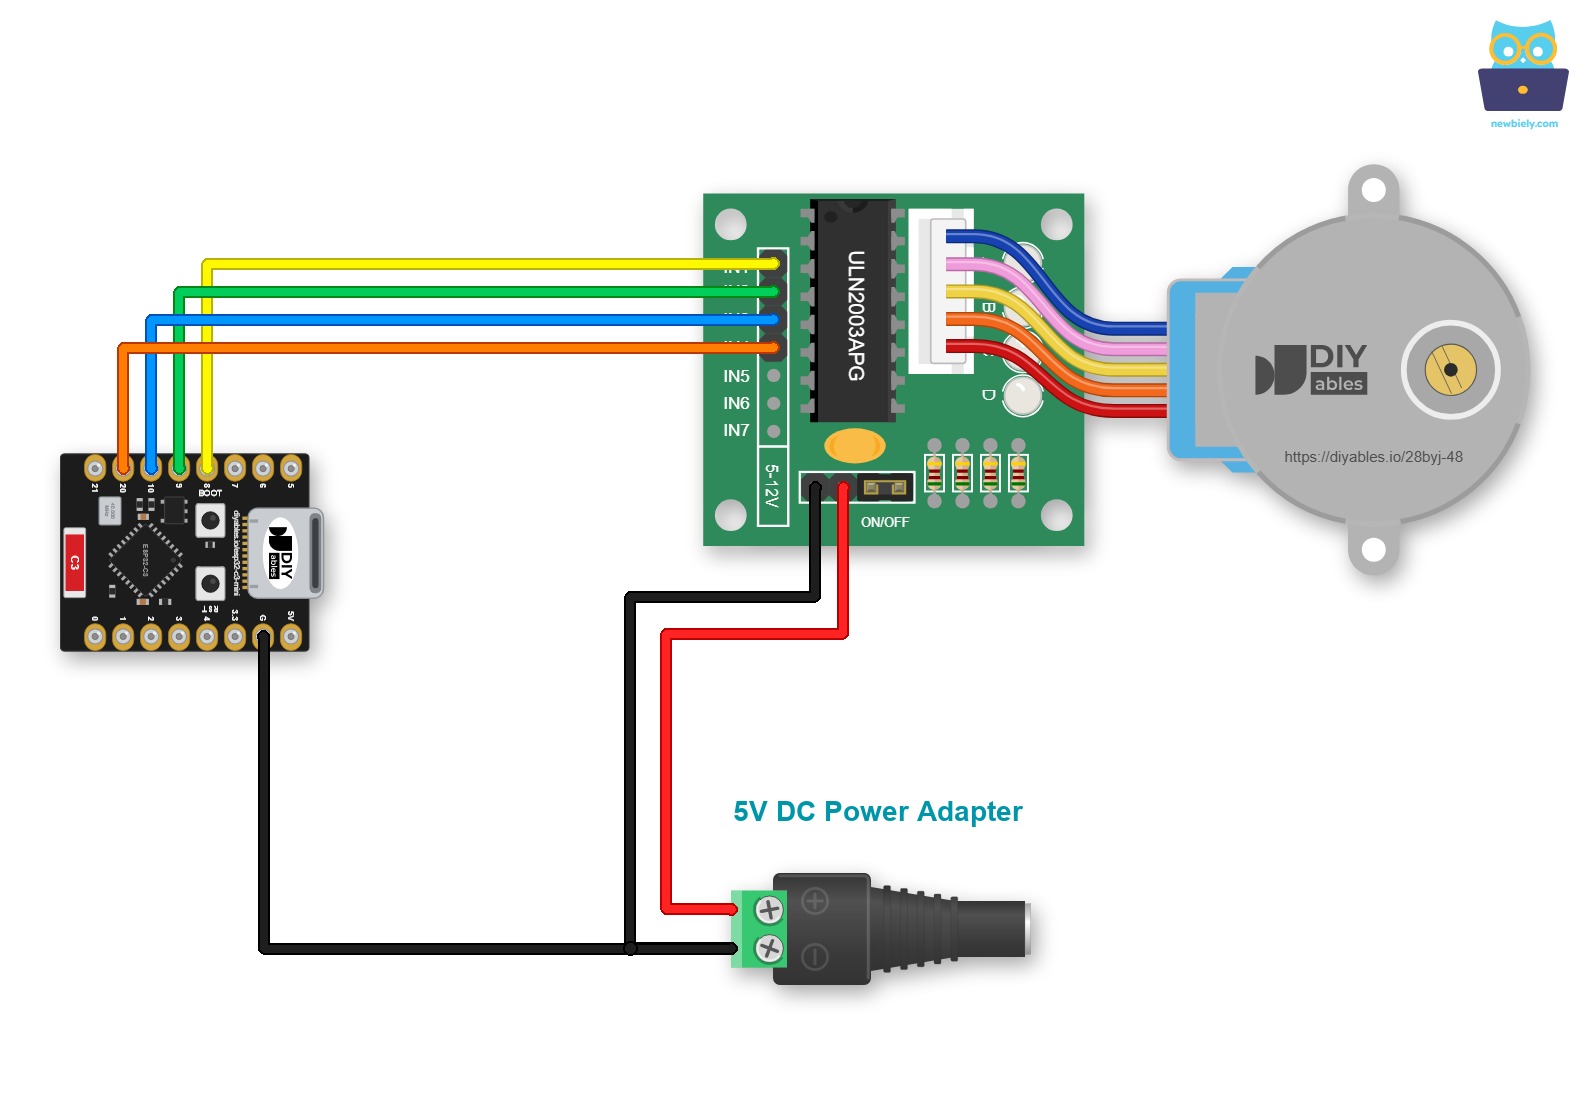
This image is created using Fritzing. Click to enlarge image
Wiring connections for ESP32 C3 Super Mini and ULN2003 driver:
| ULN2003 Pin | ESP32 C3 Super Mini Pin |
|---|---|
| IN1 | GPIO8 |
| IN2 | GPIO9 |
| IN3 | GPIO10 |
| IN4 | GPIO20 |
| GND | GND |
| VDD | 5V External Power Supply |
| Motor Connector | 28BYJ-48 Motor Connector |
| Power Supply GND | GND (shared with ESP32 and ULN2003) |
Note: The wire colors on the 28BYJ-48 stepper motor don't matter - simply plug the male connector into the female connector on the ULN2003 driver module.
How To Program to Control a Stepper Motor
Understanding stepper motor control methods helps you choose the right approach for your ESP32 C3 Super Mini project.
Three main stepper motor control methods:
- Full-Step: Basic method, provides full torque, suitable for most beginner projects
- Half-Step: Doubles resolution, smoother movement, slightly reduced torque
- Micro-Step: Highest resolution, smoothest operation, requires specialized drivers
Why we recommend the AccelStepper library:
- Non-blocking operation: ESP32 C3 Super Mini can perform other tasks while controlling the motor
- Smooth acceleration: Gradual speed changes prevent motor stalling
- Multiple motor support: Control several stepper motors independently and simultaneously
- Flexible control: Supports both full-step and half-step driving modes
- Easy to use: Simple functions for beginners
Why avoid the built-in Arduino Stepper library:
- Blocking: Freezes ESP32 during motor operation
- Limited features: Lacks acceleration and advanced control
- Poor multi-motor support: Cannot control multiple motors efficiently
Note: The AccelStepper library does not support micro-step driving, but this is rarely needed for beginner projects.
ESP32 C3 Super Mini Code - Single Stepper Motor
This code demonstrates how to control one 28BYJ-48 stepper motor using the ESP32 C3 Super Mini and AccelStepper library.
What this stepper motor code does:
- Initializes the stepper motor with proper settings for 28BYJ-48
- Rotates one full revolution clockwise
- Rotates two full revolutions counter-clockwise
- Rotates two full revolutions clockwise
- Repeats this pattern continuously
- Uses acceleration for smooth motor movement
Detailed Instructions
- New to ESP32 C3 Mini? Complete our Getting Started with ESP32 C3 Mini tutorial first to set up your development environment.
- Install AccelStepper library: Open Library Manager in Arduino IDE, search "AccelStepper", and install the library by Mike McCauley
- Search for AccelStepper created by Mike McCauley
- Set up environment: If new to ESP32 C3 Super Mini, follow the setup tutorial first
- Wire components: Connect the stepper motor and ULN2003 driver according to the wiring diagram above
- Connect ESP32: Plug your ESP32 C3 Super Mini into your computer with a USB Type-C cable
- Select board: Choose "ESP32 C3 Super Mini" and the correct COM port in Arduino IDE
- Upload code: Copy the code, paste it into Arduino IDE, and click Upload
- Observe motor: Watch the stepper motor rotate in the programmed pattern (1 rev CW, 2 rev CCW, 2 rev CW, repeat)
- Open Serial Monitor: View status messages at 115200 baud rate
- Pro Tip: Adjust the setMaxSpeed() and setAcceleration() values to change motor speed and smoothness - lower values make slower, smoother movements.
Serial Monitor Output
How to Control Multiple 28BYJ-48 Stepper Motors
Learn how to control two or more stepper motors independently at the same time using the ESP32 C3 Super Mini.
Benefits of controlling multiple stepper motors:
- Each motor moves independently with different speeds and directions
- Perfect for robotics projects requiring coordinated movement
- ESP32 has enough pins to control 2-3 stepper motors easily
- AccelStepper library handles simultaneous control smoothly
Wiring Diagram for Two 28BYJ-48 Stepper Motors
This diagram shows how to connect two stepper motors to the ESP32 C3 Super Mini using two ULN2003 driver modules.
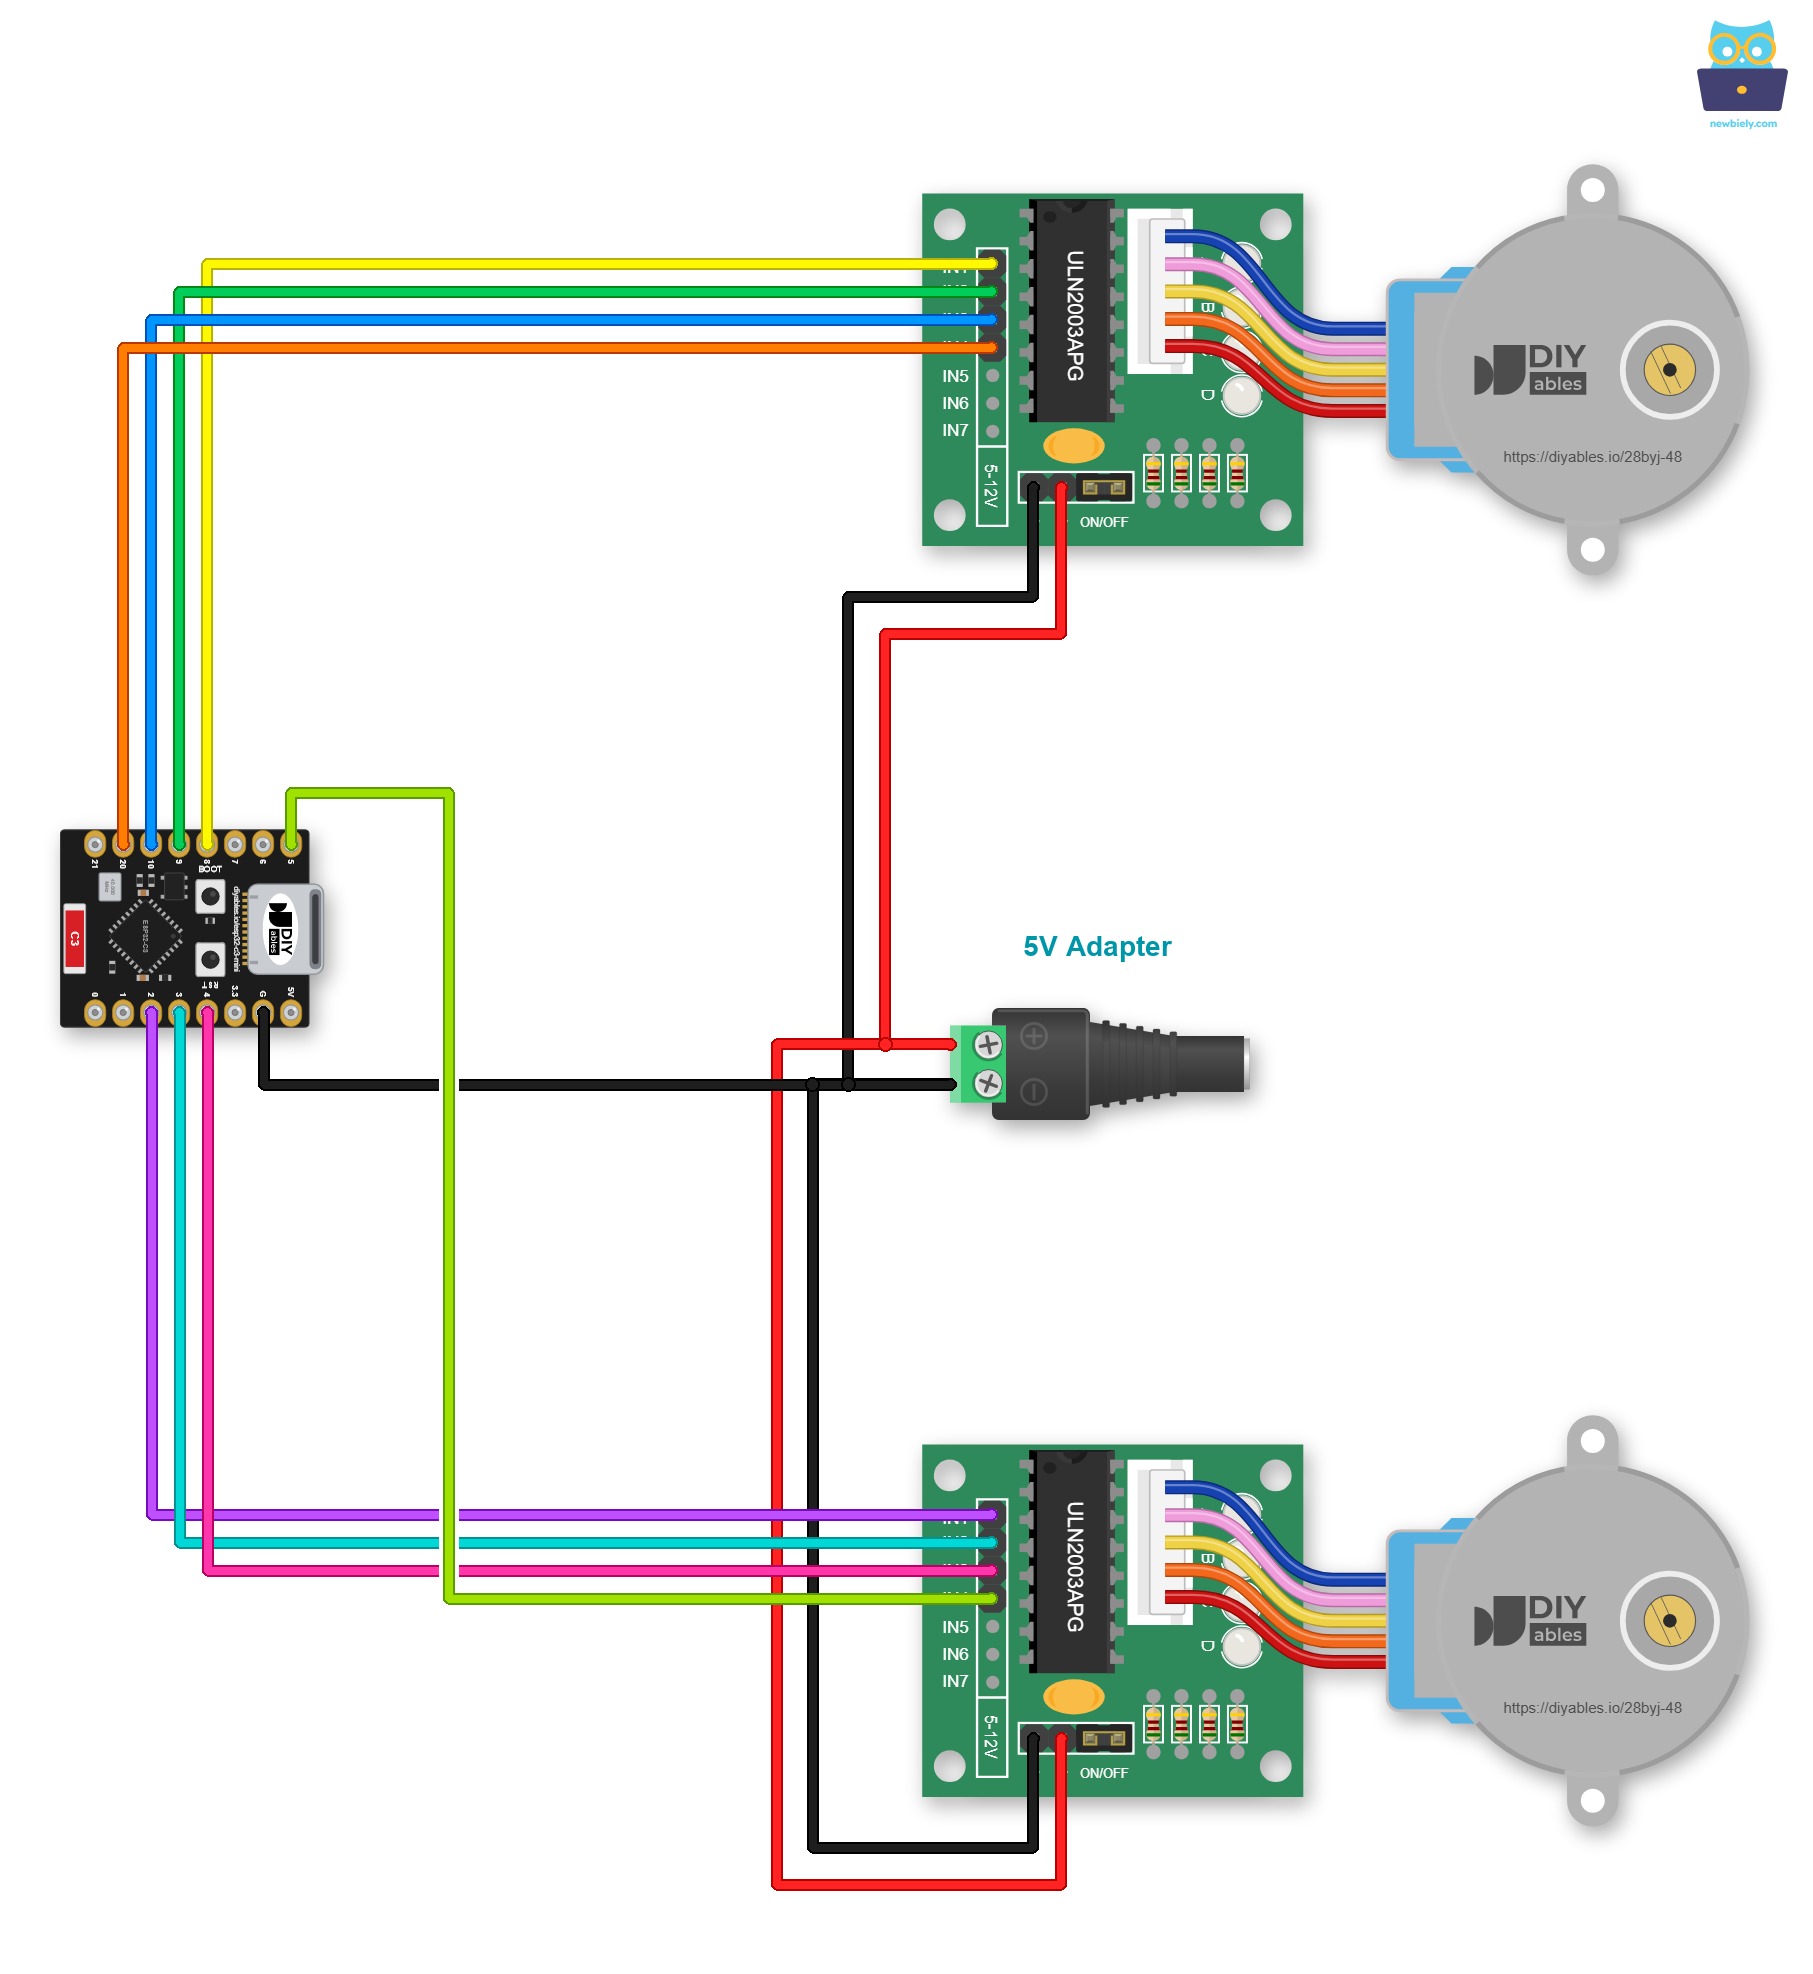
This image is created using Fritzing. Click to enlarge image
Wiring connections for two stepper motors:
| Component | ESP32 C3 Super Mini Pin |
|---|---|
| ULN2003 #1 - IN1 | GPIO8 |
| ULN2003 #1 - IN2 | GPIO9 |
| ULN2003 #1 - IN3 | GPIO10 |
| ULN2003 #1 - IN4 | GPIO20 |
| ULN2003 #2 - IN1 | GPIO2 |
| ULN2003 #2 - IN2 | GPIO3 |
| ULN2003 #2 - IN3 | GPIO4 |
| ULN2003 #2 - IN4 | GPIO5 |
| Both ULN2003 GND | GND |
| Both ULN2003 VDD | 5V External Power Supply |
| Power Supply GND | GND (shared with ESP32 and both drivers) |
Note: Both ULN2003 modules share the same external 5V power supply and common ground with the ESP32 C3 Super Mini.
ESP32 C3 Super Mini Code for Two 28BYJ-48 Stepper Motors
This code demonstrates simultaneous control of two stepper motors with independent movement patterns.
What this multi-stepper code does:
- Controls two stepper motors completely independently
- Each motor rotates at different speeds
- Motors move in opposite directions
- Demonstrates non-blocking operation
- Shows how to coordinate multiple motors in one program
Applications and Project Ideas
Use the ESP32 C3 Super Mini with 28BYJ-48 stepper motors in these exciting projects:
- Camera slider: Build an automated camera dolly for smooth time-lapse videos
- XY plotter: Create a drawing robot that plots designs on paper
- Automatic blinds: Control window blinds with scheduled or remote operation
- Pan-tilt mechanism: Make a camera mount that rotates horizontally and vertically
- Analog clock: Design a large wall clock with precise stepper motor hands
- Conveyor belt: Build a small sorting or transport system for objects
- Solar tracker: Create a panel that follows the sun throughout the day
- Robotic arm: Construct a simple 2-3 axis arm for pick-and-place tasks
Video Tutorial
Watch the video below for a visual walkthrough of this project.
...VIDEO https://www.youtube.com/watch?v=EXAMPLE_VIDEO_ID_HERE
...VIDEO
Challenge Yourself
Test your ESP32 C3 Super Mini stepper motor skills with these progressively challenging exercises:
- Easy: Modify the code to make the motor rotate 5 full revolutions clockwise, then stop
- Easy: Change the motor speed by adjusting setMaxSpeed() to make it rotate twice as fast
- Medium: Create a pattern where the motor rotates 45 degrees, pauses 1 second, then repeats
- Medium: Add a push button that reverses the motor direction when pressed
- Advanced: Build a simple clock with two stepper motors for hour and minute hands
- Advanced: Create a program that accepts Serial Monitor commands to control motor position (e.g., "MOVE 1000" or "HOME")